I moderated the robotics panel at Roboflow’s Visual Intelligence Summit. I was joined by James Chivers from BOPA, Sai Vinayak Ganesh from Medra, and Shreyas Gatuku from Standard Bots.
We talked about what it takes to get robots working outside a controlled environment: the things that go wrong, what teams learn from deployments, and how to make the technology useful to the people operating it.
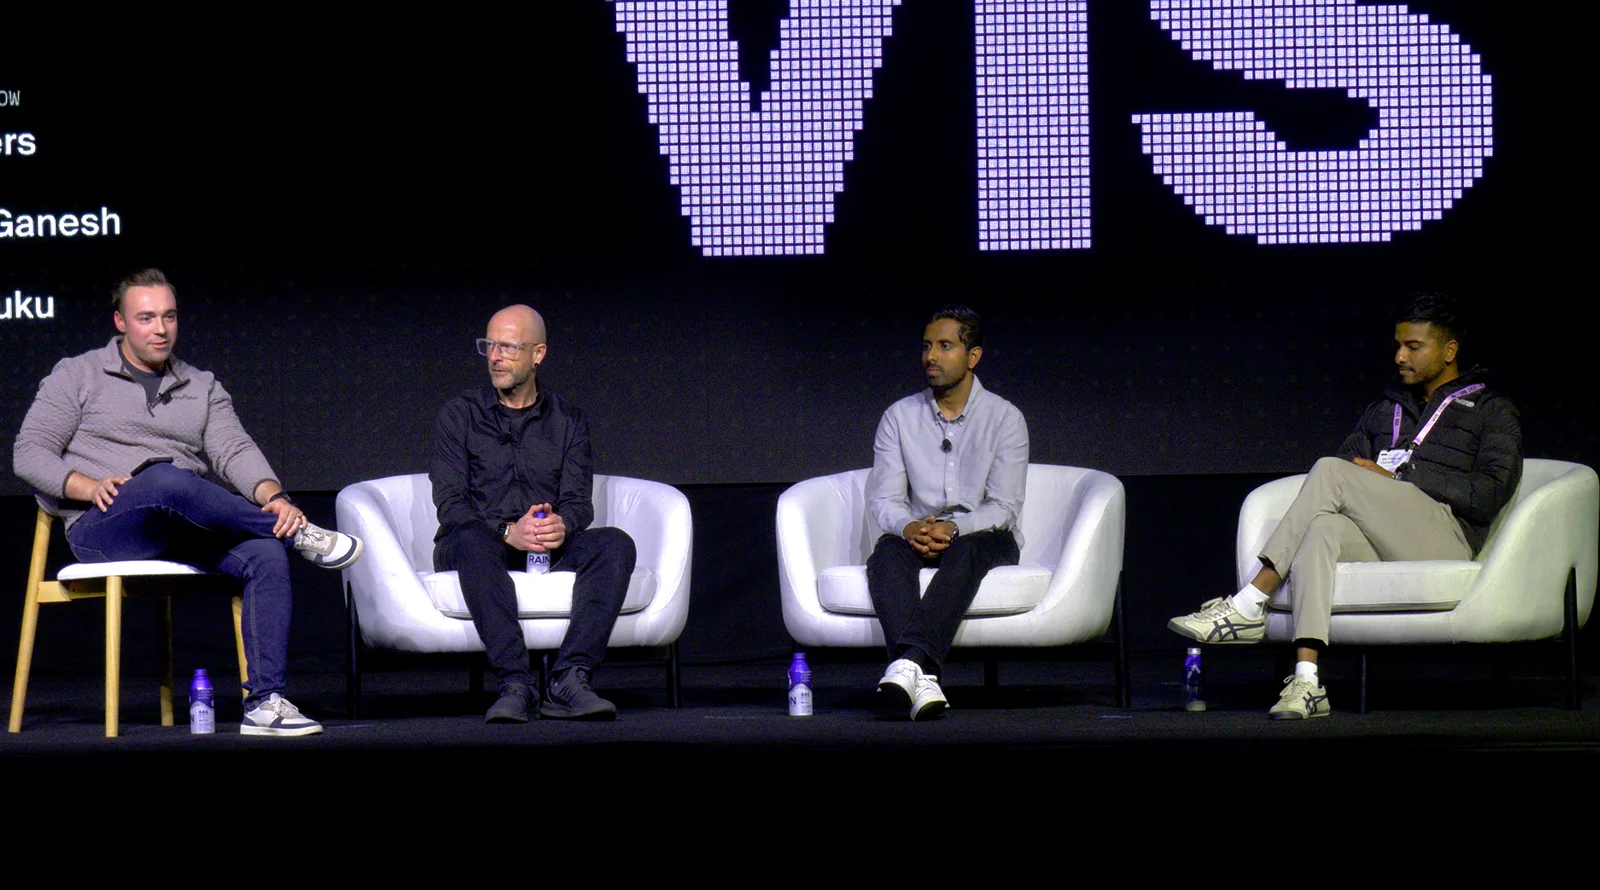
Watch the full panel on YouTube or browse the VIS session recordings.
What we got into
The field finds problems the lab misses. James shared how insects interfered with cameras during night operations and how farm dogs introduced a new obstacle for their autonomous tractors. Those were problems the team had to address in the field. Watch from 6:38.
Robots need to check their own work. Shreyas described a robot repeatedly trying to load a part into an occupied vise. Engineers had been resetting the scene during testing; customers weren’t going to do that. Vision gave them a way to check whether a step succeeded before continuing. Watch from 9:03.
The outcome matters as much as the motion. Sai explained why repeating a pipetting motion isn’t enough. A robot has to handle the experiment correctly, and scientists need to understand the data and decisions they get back. Watch from 11:12.
We also spent time on the product side: giving farmers, factory operators, and scientists interfaces they can use without becoming robotics experts. That discussion starts at 13:07.